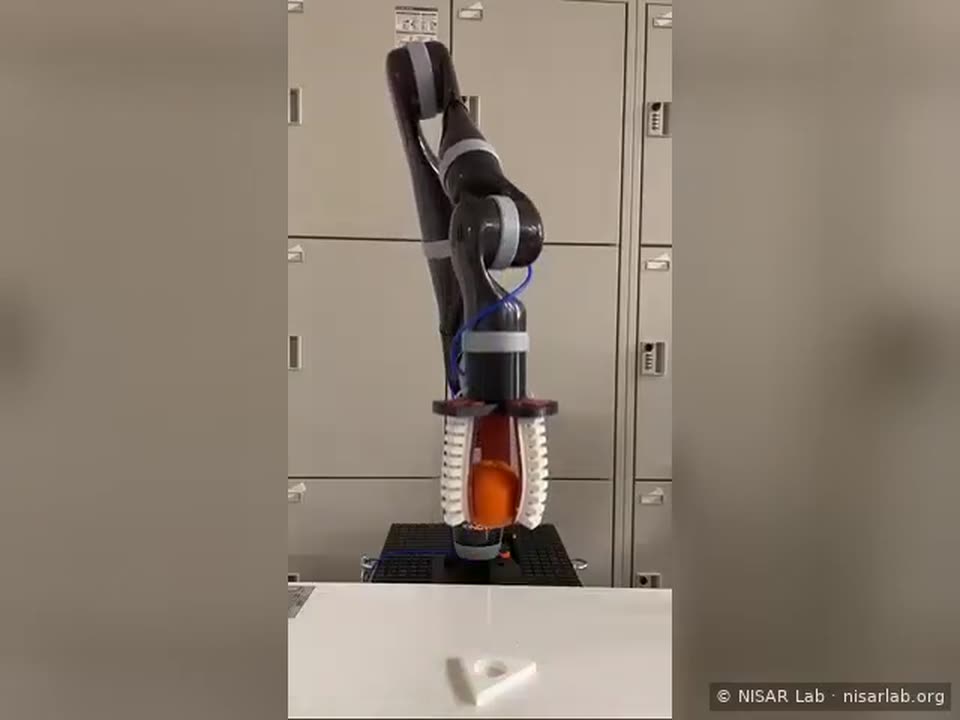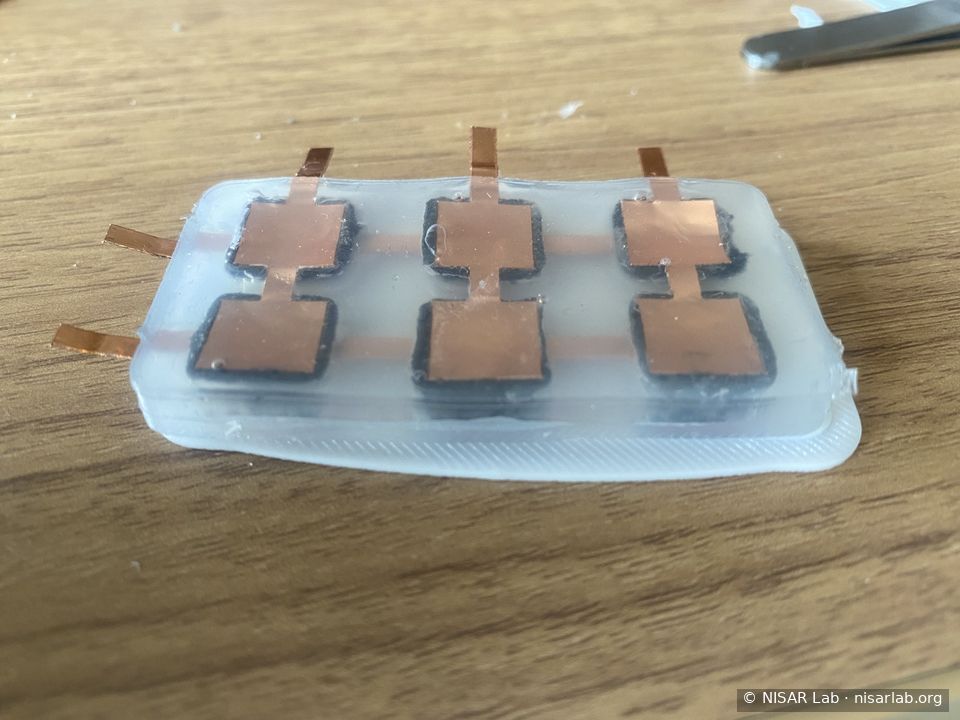
A six-pad contact sensor made from liquid-metal (eGaIn) elastomer foam and built into a soft robotic gripper finger, so the gripper can sense where and how hard it touches. The thesis documents the full fabrication route and takes the material from the lab bench into a working robotic sensor for the first time.

Connor William McGregor
M.Eng. 2026; after graduating, joined bf1systems (motorsport & automotive electronics), Norfolk, UK
All lab members →Publications
1
C. W. McGregor, J. Char, F. Haque, S. Nisar
30th Int. Symposium on Artificial Life and Robotics (AROB) 2025