This project is in progress. Details are coming soon.

This project is in progress. Details are coming soon.
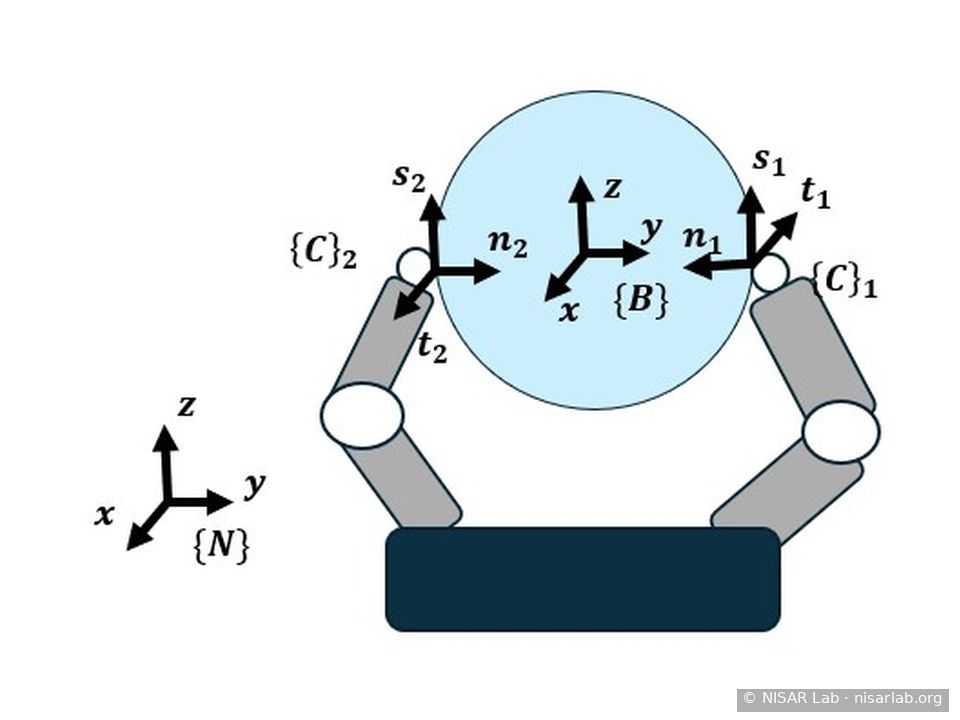
A framework for evaluating robot grasps that links theory to practice.
 Ganganath J. A. Gajitha NanayakkaraLab Project (B.Sc.) · 2025
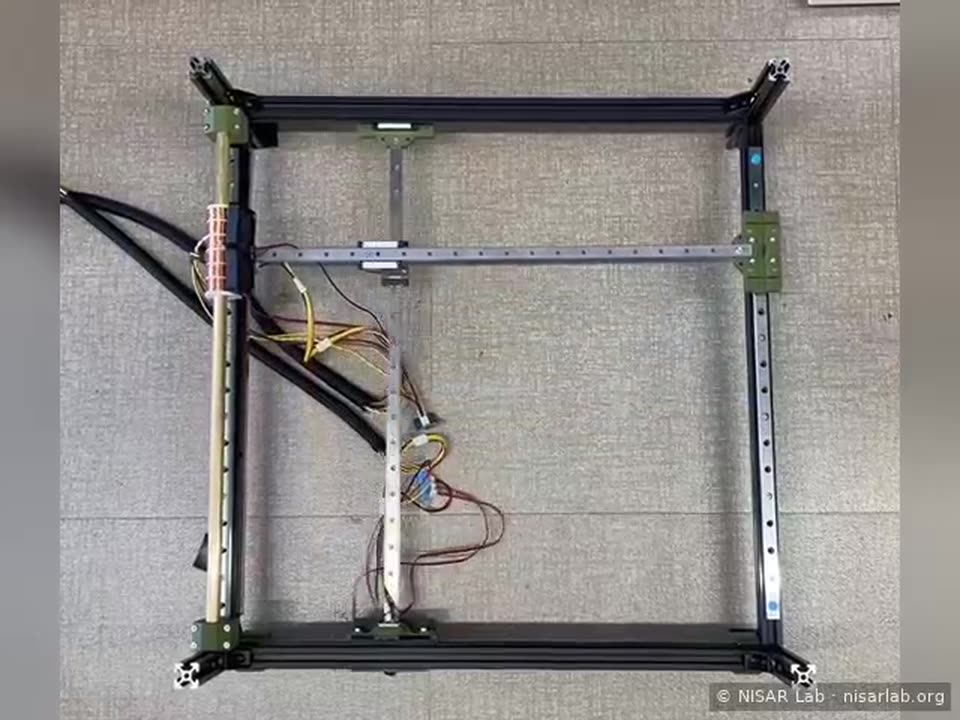
Design and development of an agile linear-actuator system for faster FDM 3D printing, demonstrated on a gantry that tracks printing paths.
 Jacob Christian CharLab Project (B.Sc.) · 2025
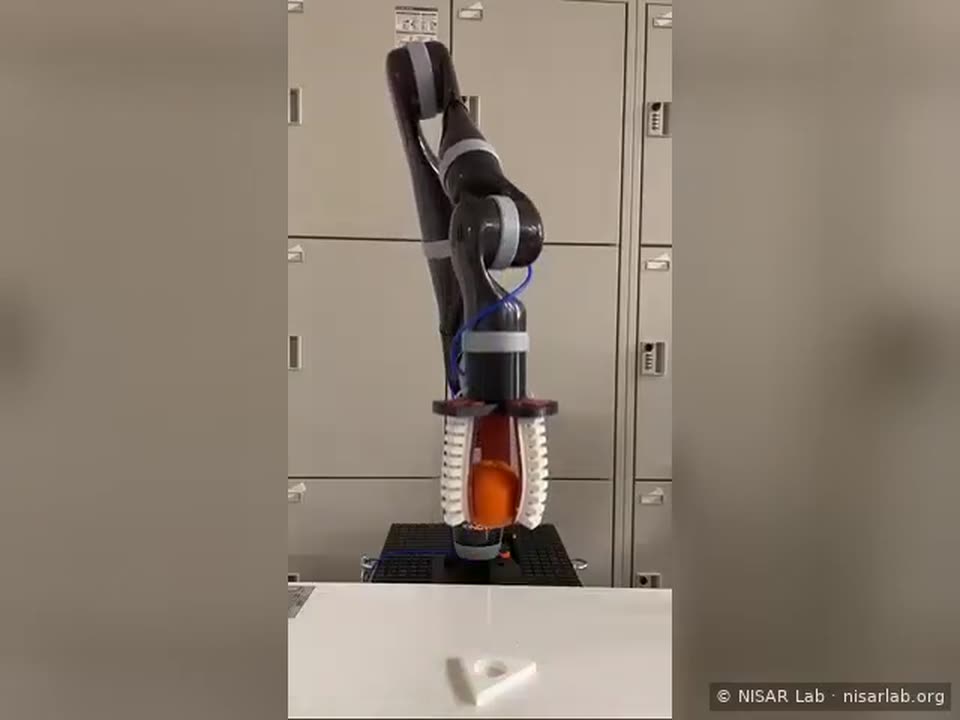
Monolithic soft robotic grippers 3D-printed in 60A and 70A TPU, among the most flexible commercially available filaments, with no silicone casting.
 Zeinelabden Yousef Khalid MeitaniLab Project (B.Sc.) · 2025