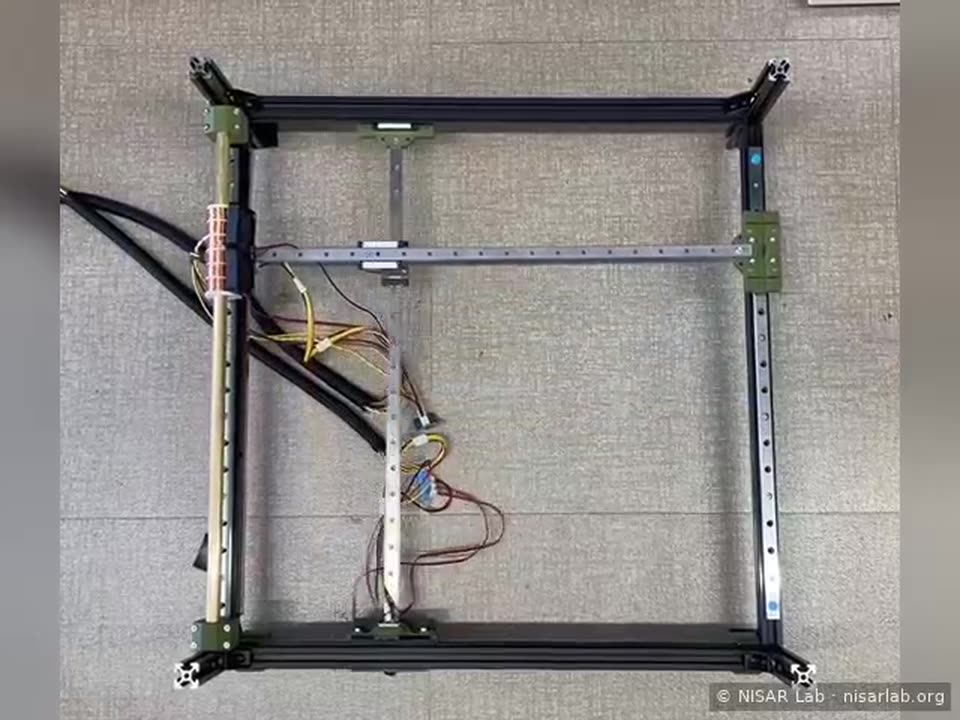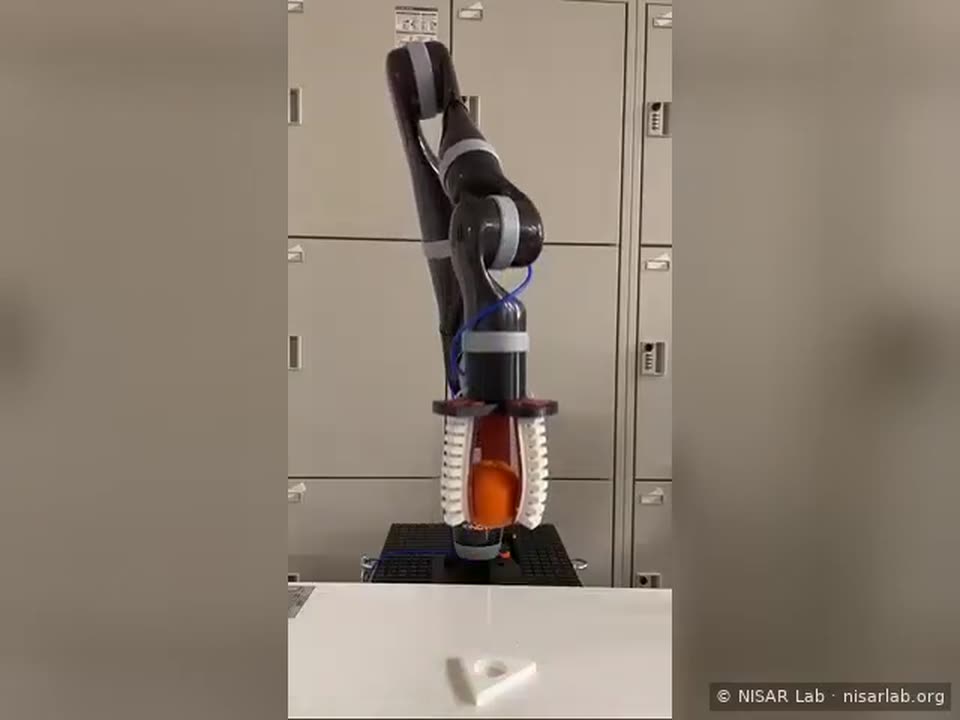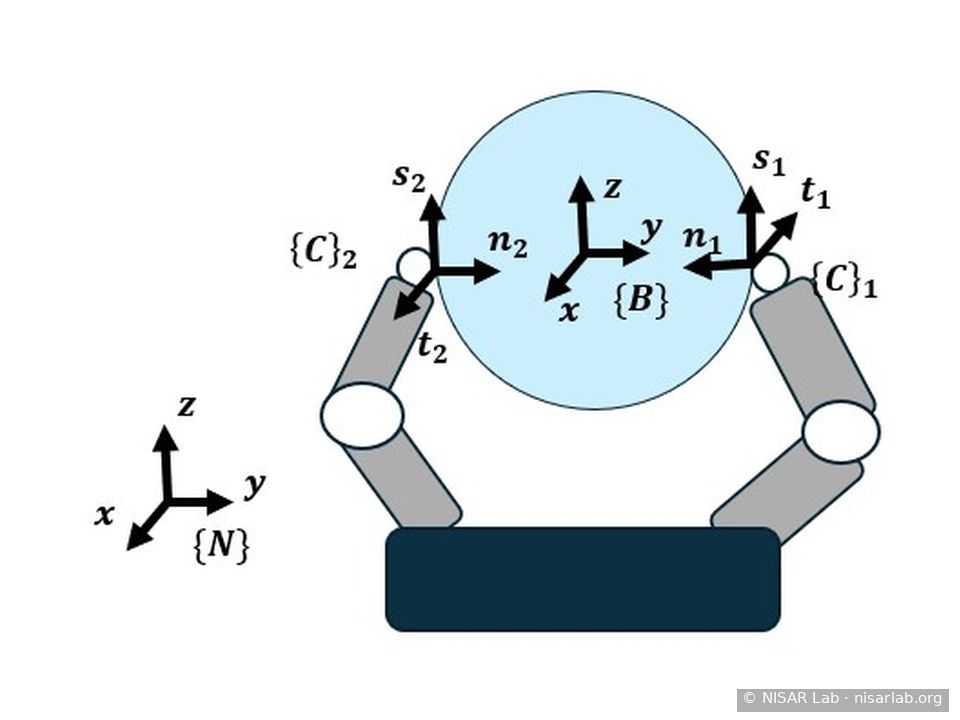
A framework for evaluating robot grasps that links theory to practice. It shows that four non-coplanar contact points are the minimum for a stable 3D grasp under the hard-finger contact model, and introduces a Grasp Quality Index that combines stability, dexterity and isotropy into one task-adaptable score.
Publications
1
G. J. A. G. Nanayakkara, P. Suriyasomboon, S. Nisar
30th Int. Symposium on Artificial Life and Robotics (AROB) 2025
2
A Minimal-Contact Grasp Stability Framework for Robust Robotic Grasping Thesis
G. G. Nanayakkara
Bachelor's thesis (Lab Project), Kyoto University of Advanced Science, Kyoto, Japan · Advisor: S. Nisar
3
G. G. Nanayakkara, K. Meitani, J. Char, F. Haque, N. Ranadive, A. Majumder, S. Nisar
42nd Annual Conf. of the Robotics Society of Japan (RSJ) 2024