We design soft pneumatic actuators, adaptive grippers, and 3D-printed compliant mechanisms that grasp delicate and irregular objects safely. Our work investigates actuator geometry, material selection, and integration into multi-finger robotic hands and rehabilitation devices.
FAYRA, a foldable soft robotic arm for wheelchair users developed in the lab, was a Japan national runner-up in the James Dyson Award 2025. Project page →
Student projects 7
Every student in the lab leads one distinct project.
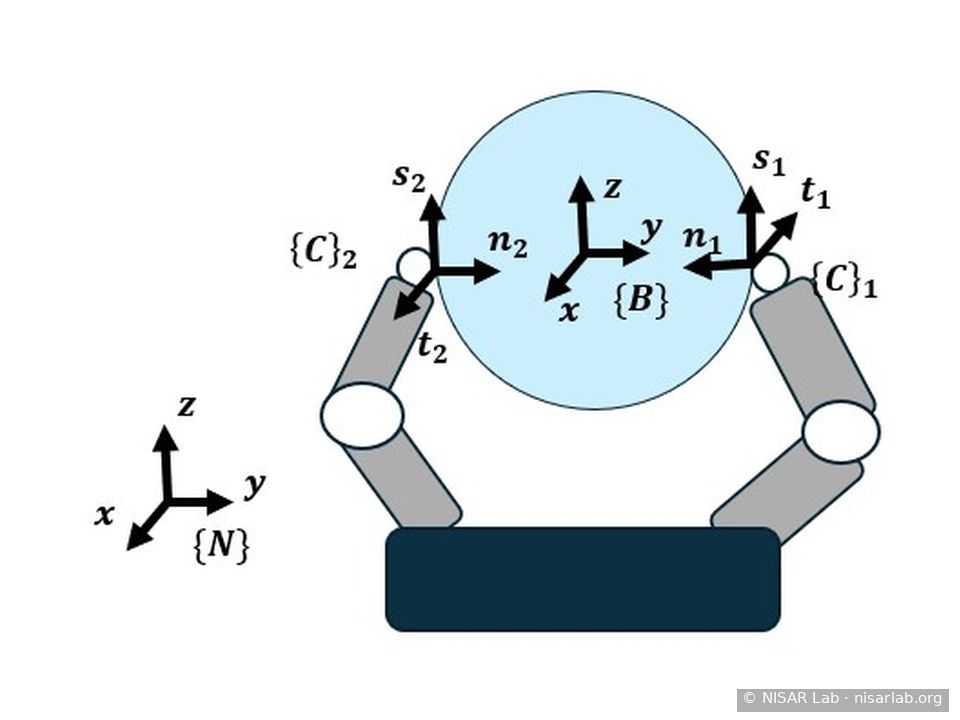
Minimal-contact grasp stability framework
A framework for evaluating robot grasps that links theory to practice.
 Ganganath J. A. Gajitha NanayakkaraLab Project (B.Sc.) · 2025
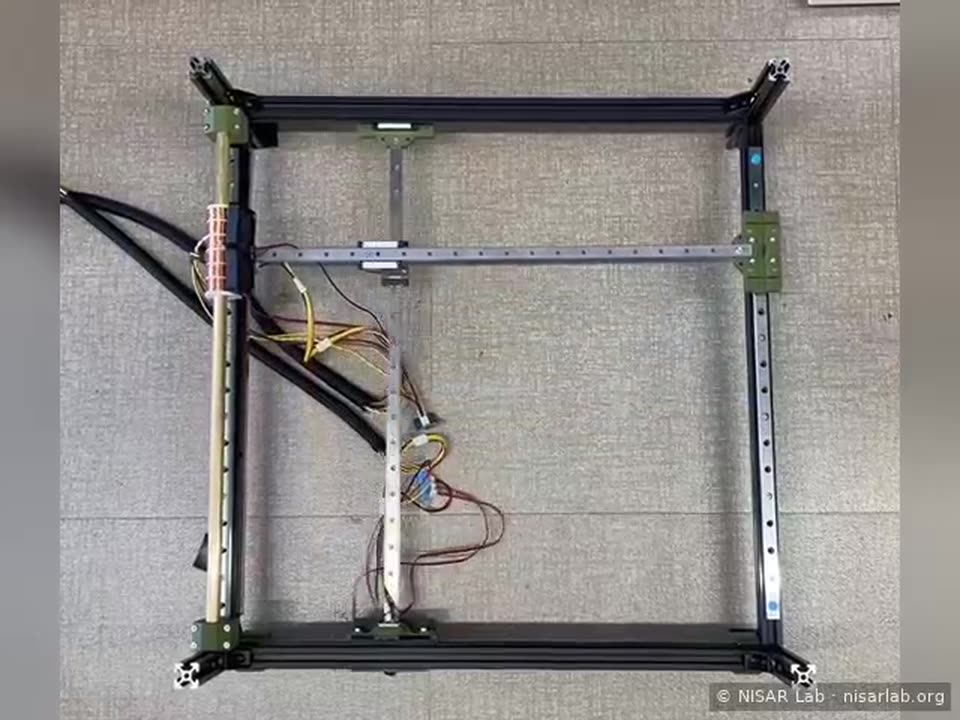
Agile linear actuators for fast 3D printing
Design and development of an agile linear-actuator system for faster FDM 3D printing, demonstrated on a gantry that tracks printing paths.
 Jacob Christian CharLab Project (B.Sc.) · 2025
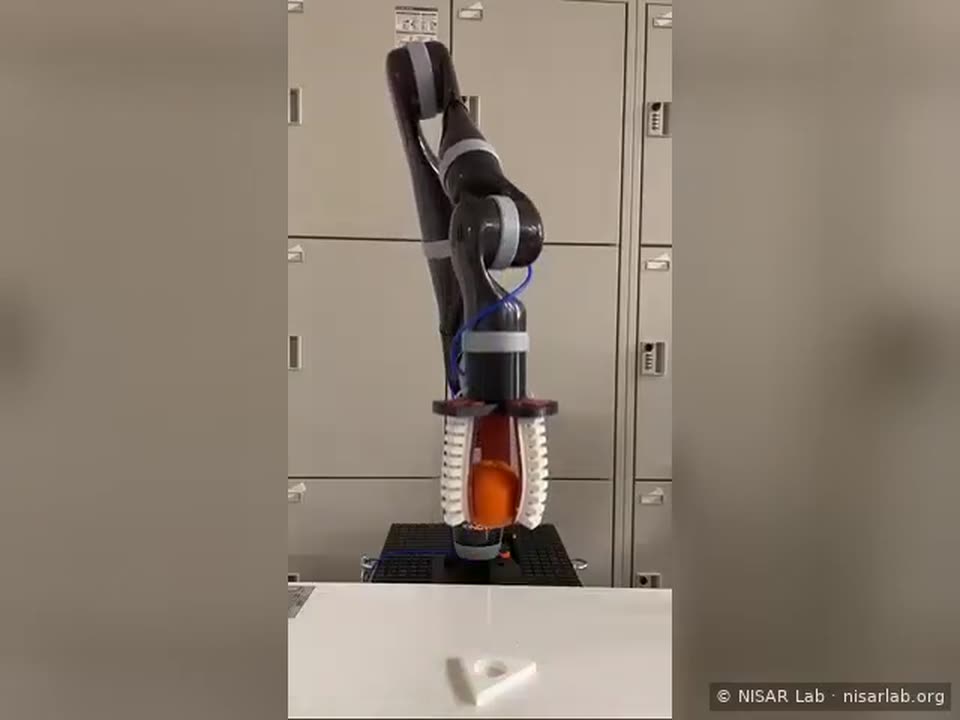
3D-printed soft grippers in ultra-flexible TPU
Monolithic soft robotic grippers 3D-printed in 60A and 70A TPU, among the most flexible commercially available filaments, with no silicone casting.
 Zeinelabden Yousef Khalid MeitaniLab Project (B.Sc.) · 2025
Soft assistive robot arm
Project in progress
 Konain AbbasMaster's research · ongoing
Wearable soft exosuit
Project in progress
 Julker NayeenLab Project · ongoing
Completed projects
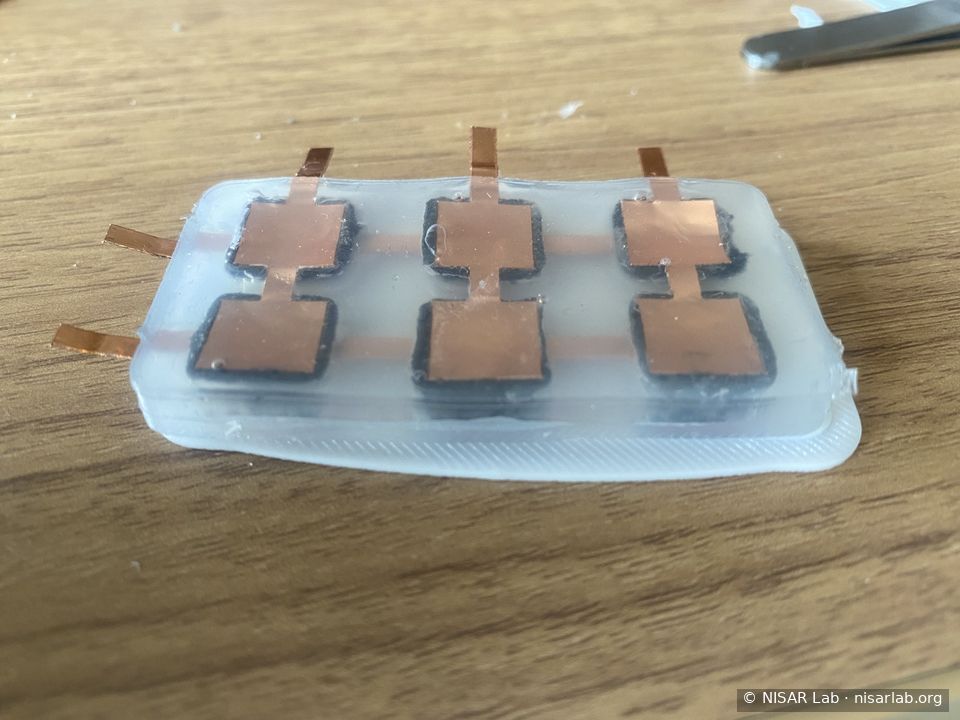
Liquid-metal touch sensor for soft grippers
A six-pad contact sensor made from liquid-metal (eGaIn) elastomer foam and built into a soft robotic gripper finger, so the gripper can sense where and how hard it touches.
 Connor William McGregorMaster's thesis · 2026
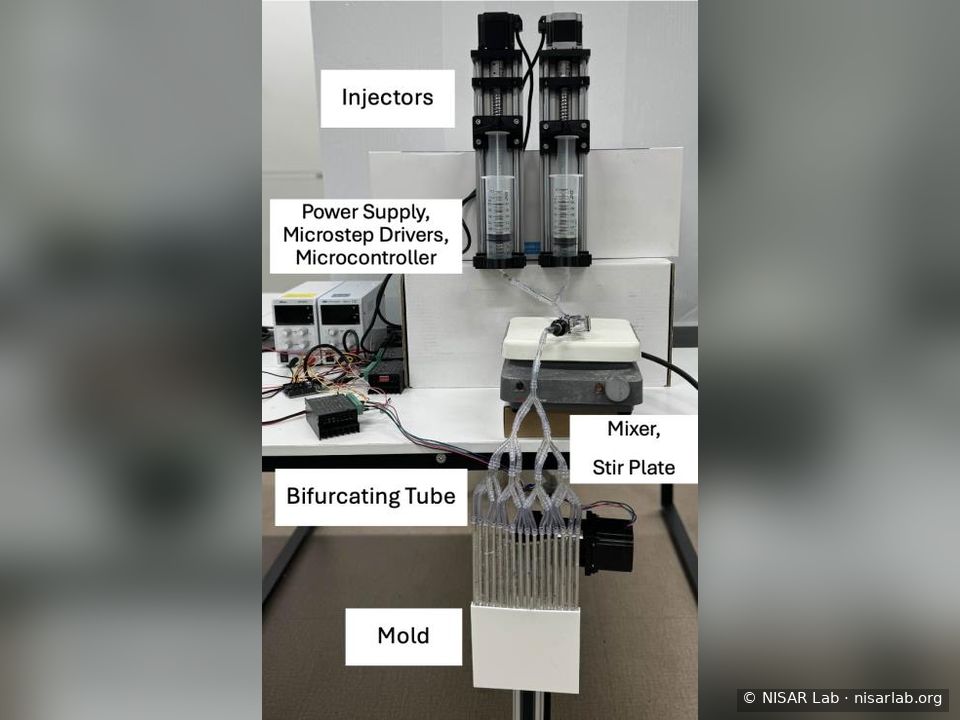
Automated agarose gel-gradient system
A machine that automatically mixes and dispenses two gels of different concentration to form gel gradients, a routine but labour-intensive task in bioscience labs.